Loading...
Searching...
No Matches
rclcpp Directory Reference
Directory dependency graph for rclcpp:
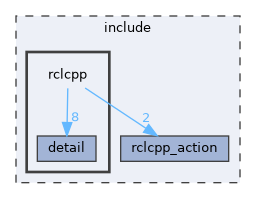
Directories | |
| detail | |
Files | |
| client.hpp | |
| rclcpp::Client<S> — the arena-registered (callback-style) service client, and Client<S>::SharedPtr = rclcpp::ClientHandle<S>. | |
| executor.hpp | |
| rclcpp::Executor — drives transport I/O and dispatches callbacks. | |
| fixed_sequence.hpp | |
| rclcpp::FixedSequence<T,N> — fixed-capacity sequence container. | |
| fixed_string.hpp | |
| rclcpp::FixedString<N> — fixed-capacity null-terminated string. | |
| future.hpp | |
| rclcpp::Future<T> — single-shot deferred result. | |
| guard_condition.hpp | |
| rclcpp::GuardCondition — cross-thread wake source. | |
| node.hpp | |
| rclcpp::Node and global session helpers. | |
| publisher.hpp | |
| rclcpp::Publisher<M> — typed topic publisher. | |
| qos.hpp | |
| rclcpp::QoS — full DDS-shaped QoS settings (Phase 108.B.7). | |
| rclcpp.hpp | |
| result.hpp | |
| rclcpp::Result, rclcpp::ErrorCode, and the RCLCPP_TRY macro. | |
| service.hpp | |
| rclcpp::Service<S> — the arena-registered (callback-style) service server, and Service<S>::SharedPtr = rclcpp::ServiceHandle<S>. | |
| span.hpp | |
| rclcpp::Span<T> and rclcpp::StringView — non-owning views. | |
| stream.hpp | |
| rclcpp::Stream<T> — multi-shot message receiver. | |
| subscription.hpp | |
| rclcpp::Subscription<M> — the typed DISPATCH subscriber: the arena owns it and the executor calls your handler. | |
| timer.hpp | |
| rclcpp::Timer — periodic callback driven by the executor. | |
