Loading...
Searching...
No Matches
stream.hpp File Reference
rclcpp::Stream<T> — multi-shot message receiver. More...
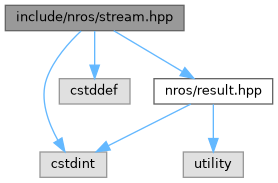
Include dependency graph for stream.hpp:
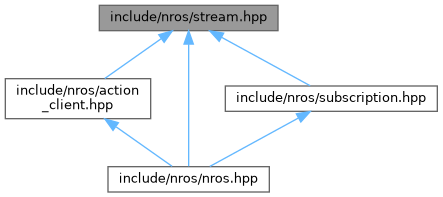
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | rclcpp::Stream< T > |
Namespaces | |
| namespace | rclcpp |
| namespace | rclcpp_action |
Functions | |
| nros_cpp_ret_t | nros_cpp_spin_once (void *handle, int32_t timeout_ms) |
| uint64_t | nros_cpp_time_ns (void) |
Detailed Description
rclcpp::Stream<T> — multi-shot message receiver.
Function Documentation
◆ nros_cpp_spin_once()
| nros_cpp_ret_t nros_cpp_spin_once | ( | void * | handle, |
| int32_t | timeout_ms ) |
◆ nros_cpp_time_ns()
| uint64_t nros_cpp_time_ns | ( | void | ) |
Monotonic time in nanoseconds. Stream::wait_next() budgets its spin loop by wall-clock, not iteration count (Phase 118.C — same fix Future::wait() got in Phase 89.2; Stream was missed).
