rclcpp::QoS — full DDS-shaped QoS settings (Phase 108.B.7).
More...
#include <stdint.h>#include "rclcpp/duration.hpp"#include "rclc/visibility_control.h"#include "rclcpp/logging.hpp"
Include dependency graph for qos.hpp:
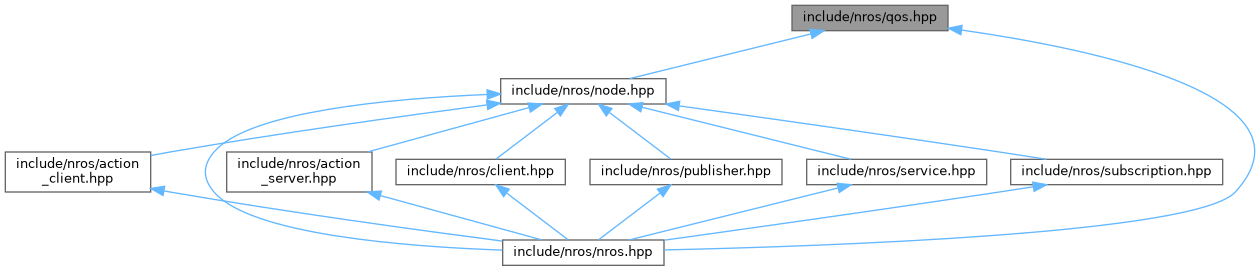
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | rclcpp::ClockQoS |
rclcpp::ClockQoS — KEEP_LAST(1), BEST_EFFORT, VOLATILE. ADOPT. More... | |
| class | rclcpp::detail::is_qos_arg< F > |
| struct | nros_cpp_qos_t |
| class | rclcpp::ParameterEventsQoS |
| class | rclcpp::ParametersQoS |
| class | rclcpp::QoS |
| struct | rclcpp::detail::qos_arg_strip< F > |
| struct | rclcpp::detail::qos_arg_strip< const F & > |
| struct | rclcpp::detail::qos_arg_strip< const F > |
| struct | rclcpp::detail::qos_arg_strip< F & > |
| class | rclcpp::RosoutQoS |
| class | rclcpp::SensorDataQoS |
rmw_qos_profile_sensor_data — KEEP_LAST(5), BEST_EFFORT, VOLATILE. ADOPT. More... | |
| class | rclcpp::ServicesQoS |
| class | rclcpp::SystemDefaultsQoS |
Namespaces | |
| namespace | rclcpp |
| namespace | rclcpp::detail |
Functions | |
| constexpr QoS | rclcpp::KeepAll () |
rclcpp::KeepAll(). Same ADOPT-BOUNDED note as KeepLast. | |
| constexpr QoS | rclcpp::KeepLast (::size_t depth) |
| constexpr bool | rclcpp::operator!= (const QoS &left, const QoS &right) |
| constexpr bool | rclcpp::operator== (const QoS &left, const QoS &right) |
| constexpr QoS | rclcpp::detail::qos_from_ffi (const nros_cpp_qos_t &f) |
| const char * | rclcpp::qos_policy_kind_to_cstr (uint32_t policy) |
| constexpr Duration | rclcpp::detail::qos_window_duration (uint32_t ms) |
| constexpr uint32_t | rclcpp::detail::qos_window_ms (const Duration &d) |
| const char * | rclcpp::rclc_qos_policy_kind_to_cstr (uint32_t policy) |
Detailed Description
rclcpp::QoS — full DDS-shaped QoS settings (Phase 108.B.7).
