Loading...
Searching...
No Matches
rmw_qos_profile_s Struct Reference
#include <qos.hpp>
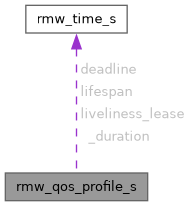
Collaboration diagram for rmw_qos_profile_s:
Public Member Functions | |
| constexpr | operator::rclcpp::QoS () const |
Detailed Description
Upstream's rmw_qos_profile_t (rmw/types.h): same fields, same order, same types. An aggregate, so upstream's brace initialisers compile.
The one addition is the conversion to rclcpp::QoS, which is what lets a profile reach a verb that takes QoS — Humble's create_service takes the struct, ours takes QoS. A profile carrying a SYSTEM_DEFAULT or UNKNOWN policy converts to a QoS carrying the same sentinel, exactly as a get_actual_qos() read-back does; no constant below carries one except liveliness, which every upstream profile leaves to the middleware.
Member Function Documentation
◆ operator::rclcpp::QoS()
|
inlineconstexpr |
Member Data Documentation
◆ avoid_ros_namespace_conventions
| bool rmw_qos_profile_s::avoid_ros_namespace_conventions |
◆ deadline
| rmw_time_t rmw_qos_profile_s::deadline |
◆ depth
| size_t rmw_qos_profile_s::depth |
◆ durability
| rmw_qos_durability_policy_t rmw_qos_profile_s::durability |
◆ history
| rmw_qos_history_policy_t rmw_qos_profile_s::history |
◆ lifespan
| rmw_time_t rmw_qos_profile_s::lifespan |
◆ liveliness
| rmw_qos_liveliness_policy_t rmw_qos_profile_s::liveliness |
◆ liveliness_lease_duration
| rmw_time_t rmw_qos_profile_s::liveliness_lease_duration |
◆ reliability
| rmw_qos_reliability_policy_t rmw_qos_profile_s::reliability |
The documentation for this struct was generated from the following file:
- include/rclcpp/qos.hpp
