Loading...
Searching...
No Matches
node.hpp File Reference
rclcpp::Node and global session helpers. More...
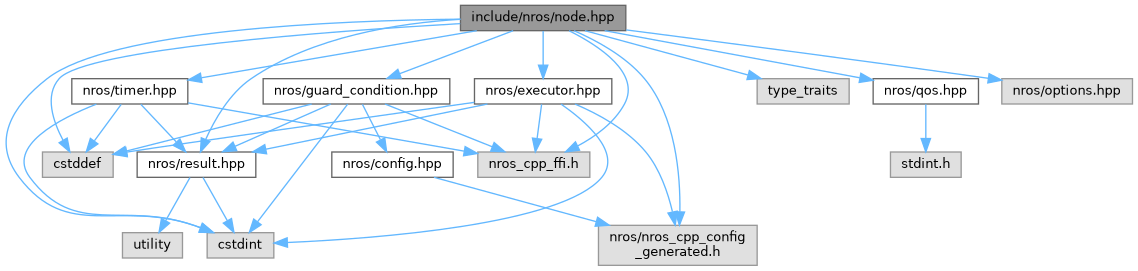
#include <cstdint>#include <cstddef>#include <type_traits>#include "rclcpp/detail/nros_cpp_ffi.h"#include "rclcpp/detail/traits.hpp"#include "rclcpp/handle.hpp"#include "rclcpp/result.hpp"#include "rclcpp/owned.hpp"#include "rclcpp/detail/hosted_block.hpp"#include "rclcpp/detail/nros_cpp_config_generated.h"#include "rclc/detail/entry_config.h"#include "rclcpp/qos.hpp"#include "rclcpp/options.hpp"#include "rclcpp/timer.hpp"#include "rclcpp/clock.hpp"#include "rclcpp/detail/declared_qos.hpp"#include "rclcpp/detail/declared_params.hpp"#include "rclcpp/node_parameters.hpp"#include "rclcpp/parameter_value.hpp"#include "rclcpp/logging.hpp"#include "rclcpp/guard_condition.hpp"#include "rclcpp/executor.hpp"#include "rclcpp/graph.hpp"#include "rclcpp/callback_group.hpp"#include "rclcpp/parameter.hpp"#include "rclcpp/detail/std_detect.hpp"
Include dependency graph for node.hpp:
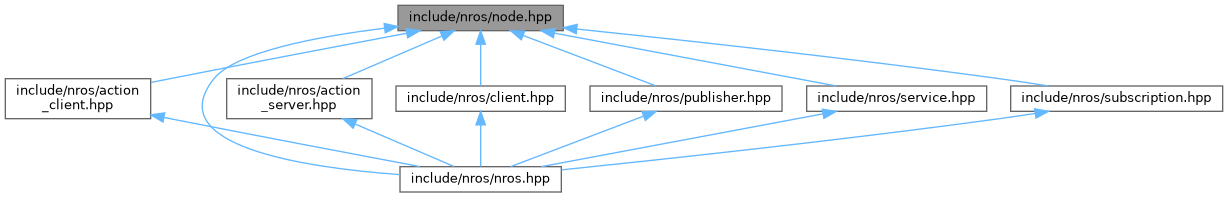
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | rclcpp::Node |
| class | rclcpp::NodeBuilder |
| struct | rclcpp::NodeHandle |
| class | rclcpp::node_interfaces::NodeInterfaceHandle< Tag > |
| One slice's handle; Tag only keeps the five spellings distinct types. More... | |
| class | rclcpp::NodeWithTimers< MaxTimers > |
Namespaces | |
| namespace | rclcpp |
| namespace | rclcpp::detail |
| namespace | rclcpp::node_interfaces |
| namespace | rclcpp_action |
Macros | |
| #define | NROS_COMPONENT_MAX_TIMERS 8 |
Functions | |
| int32_t | rclcpp::detail::apply_ros_args (void *executor, int argc, char const *const *argv) |
| Result | rclcpp::create_node (::rclcpp::Node &out, const char *name, const char *ns) |
| Result | rclcpp::create_node_on (::rclcpp::Node &out, void *executor_handle, const char *name, const char *ns) |
| const char * | rclcpp::detail::declared_durability_spelling (int ordinal) |
| The contract spelling of a durability ordinal, for the report above. | |
| const char * | rclcpp::detail::declared_reliability_spelling (int ordinal) |
| The contract spelling of a reliability ordinal, for the report above. | |
| void | rclcpp::detail::finish_declared_callback_groups (::rclcpp::Node &node, const DeclaredCallbackGroups &groups) |
| void * | rclcpp::global_handle () |
| Result | rclcpp::detail::init_honouring_ros_args (int argc, char const *const *argv, const char *name) |
| Result | rclcpp::init_in (const char *locator, uint8_t domain_id, const char *session_name) |
| Result | rclcpp::init_in (const char *locator, uint8_t domain_id, const char *session_name, const char *node_namespace) |
| Result | rclcpp::init_in (const char *locator=nullptr, uint8_t domain_id=0) |
| Result | rclcpp::init_in (int argc, char const *const *argv, const char *session_name=nullptr) |
| Result | rclcpp::init_with_rmw (const char *rmw, const char *locator=nullptr, uint8_t domain_id=0, const char *session_name="node") |
| ResultOf<::rclcpp::Node > | rclcpp::make_node (const char *name, const char *ns=nullptr) |
| bool | rclcpp::ok () |
| void | rclcpp::detail::report_callback_group_mismatch (const char *node_name, const char *how, const char *name, int len, const char *list) |
| void | rclcpp::detail::report_component_failure (const char *node_name, const char *what, int32_t code) |
| void | rclcpp::detail::report_declared_depth_mismatch (const char *node_name, const char *topic, int declared, int passed) |
| void | rclcpp::detail::report_declared_param_mismatch (const char *fqn, const char *param, const char *contract, int declared, int passed) |
| void | rclcpp::detail::report_declared_policy_mismatch (const char *node_name, const char *topic, const char *policy, const char *declared, const char *passed) |
| Result | rclcpp::shutdown_in () |
| Result | rclcpp::spin_in () |
| Result | rclcpp::spin_in (uint32_t duration_ms, int32_t poll_ms=10) |
| Result | rclcpp::spin_once (int32_t timeout_ms=10) |
Variables | |
| constexpr int32_t | rclcpp::detail::DECLARED_DEPTH_MISMATCH = -403 |
| constexpr int32_t | rclcpp::detail::DECLARED_PARAM_MISMATCH = -446 |
| constexpr int32_t | rclcpp::detail::DECLARED_QOS_MISMATCH = DECLARED_DEPTH_MISMATCH |
| constexpr uint8_t | rclcpp::kDomainIdExplicitZero = 255 |
Detailed Description
rclcpp::Node and global session helpers.
Macro Definition Documentation
◆ NROS_COMPONENT_MAX_TIMERS
| #define NROS_COMPONENT_MAX_TIMERS 8 |
Max timers a NodeWithTimers may own via the storage-free create_*_in members. Overridable per build with a #define before including this header; it is the DEFAULT depth, not a cap on what a node may ask for.
