nros C++ API
Lightweight ROS 2 client for embedded real-time systems (C++ headers)
Loading...
Searching...
No Matches
Classes | Namespaces | Typedefs | Enumerations | Functions | Variables
server.hpp File Reference
#include <cstdint>
#include <cstddef>
#include <string.h>
#include "rclcpp/detail/callback_context.hpp"
#include "rclcpp/detail/config.hpp"
#include "rclcpp/detail/entity_name.hpp"
#include "rclcpp/result.hpp"
#include "rclcpp/size_bound.hpp"
#include "rclcpp/detail/nros_cpp_ffi.h"
#include "rclcpp/node.hpp"
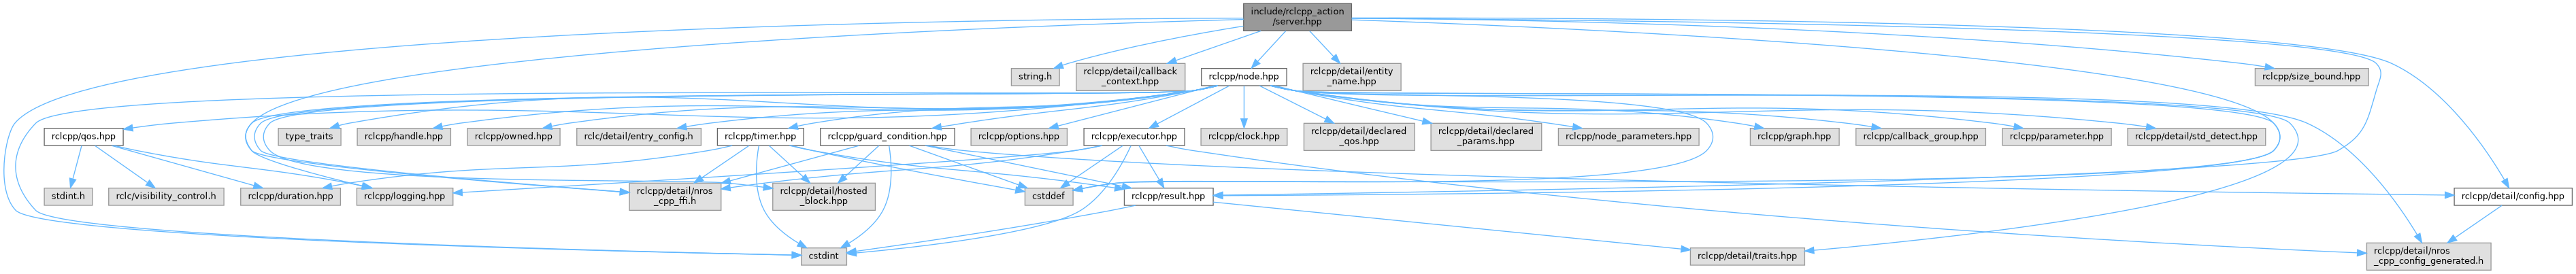
Include dependency graph for server.hpp:
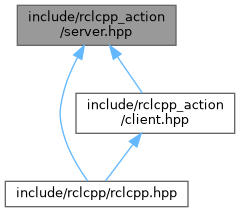
This graph shows which files directly or indirectly include this file:

Go to the source code of this file.

Classes

struct  rclcpp::detail::action_endpoint_hashes_of< A, class >
 
struct  rclcpp::detail::action_endpoint_hashes_of< A, typename nros_void_< decltype(A::SEND_GOAL_SERVICE_HASH)>::type >
 
struct  rclcpp_action::GoalUUID
 
struct  rclcpp::detail::nros_void_<... >
 
class  rclcpp_action::Server< A >
 

Namespaces

namespace  rclcpp
 
namespace  rclcpp::detail
 
namespace  rclcpp_action
 

Typedefs

typedef void(* nros_cpp_accepted_callback_t) (const uint8_t goal_id[16], void *ctx)
 
typedef int32_t(* nros_cpp_cancel_callback_t) (const uint8_t goal_id[16], void *ctx)
 
typedef int32_t(* nros_cpp_goal_callback_t) (const uint8_t goal_id[16], const uint8_t *data, size_t len, void *ctx)
 

Enumerations

enum class  rclcpp_action::CancelResponse : int8_t { rclcpp_action::REJECT = 1 , rclcpp_action::ACCEPT = 2 }
 
enum class  rclcpp_action::CancelReturnCode : int8_t { rclcpp_action::Ok = 0 , rclcpp_action::Rejected = 1 , rclcpp_action::UnknownGoal = 2 , rclcpp_action::GoalTerminated = 3 }
 
enum class  rclcpp_action::GoalResponse : int8_t { rclcpp_action::REJECT = 1 , rclcpp_action::ACCEPT_AND_EXECUTE = 2 , rclcpp_action::ACCEPT_AND_DEFER = 3 }
 
enum class  rclcpp_action::GoalStatus : int8_t {
  rclcpp_action::Unknown = 0 , rclcpp_action::Accepted = 1 , rclcpp_action::Executing = 2 , rclcpp_action::Canceling = 3 ,
  rclcpp_action::Succeeded = 4 , rclcpp_action::Canceled = 5 , rclcpp_action::Aborted = 6
}
 

Functions

template<class A >
nros_cpp_action_hashes_t rclcpp::detail::action_endpoint_hashes ()
 
nros_cpp_ret_t nros_cpp_action_server_set_accepted_callback (void *handle, nros_cpp_accepted_callback_t accepted_cb, void *ctx)
 
nros_cpp_ret_t nros_cpp_action_server_set_callbacks (void *handle, nros_cpp_goal_callback_t goal_cb, nros_cpp_cancel_callback_t cancel_cb, void *ctx)
 
constexpr int32_t rclcpp_action::to_ffi (CancelResponse r)
 
constexpr int32_t rclcpp_action::to_ffi (GoalResponse r)
 

Variables

static const size_t rclcpp_action::ACTION_NAME_MAX = 256
 

Typedef Documentation

◆ nros_cpp_accepted_callback_t

typedef void(* nros_cpp_accepted_callback_t) (const uint8_t goal_id[16], void *ctx)

◆ nros_cpp_cancel_callback_t

typedef int32_t(* nros_cpp_cancel_callback_t) (const uint8_t goal_id[16], void *ctx)

◆ nros_cpp_goal_callback_t

typedef int32_t(* nros_cpp_goal_callback_t) (const uint8_t goal_id[16], const uint8_t *data, size_t len, void *ctx)

Function Documentation

◆ nros_cpp_action_server_set_accepted_callback()

nros_cpp_ret_t nros_cpp_action_server_set_accepted_callback ( void *  handle,
nros_cpp_accepted_callback_t  accepted_cb,
void *  ctx 
)

◆ nros_cpp_action_server_set_callbacks()
nros_cpp_ret_t nros_cpp_action_server_set_callbacks ( void *  handle,
nros_cpp_goal_callback_t  goal_cb,
nros_cpp_cancel_callback_t  cancel_cb,
void *  ctx 
)