#include <nros_generated.h>
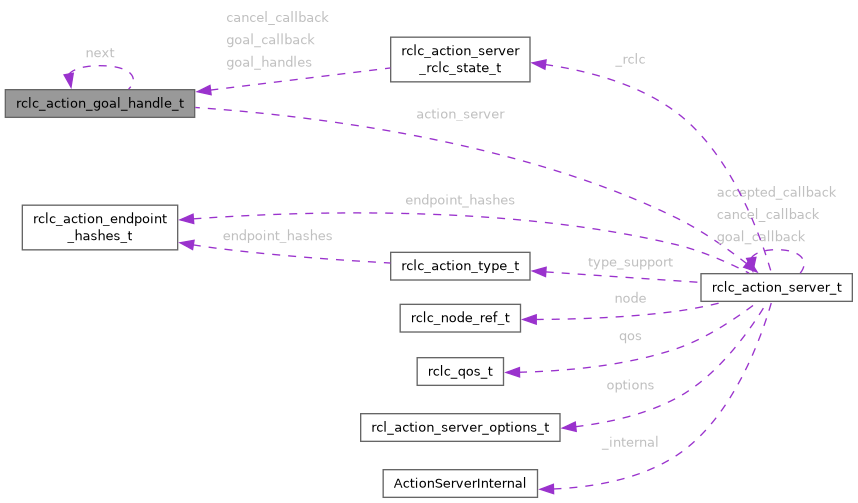
Data Fields | |
| bool | _in_use |
| struct rcl_action_server_t * | action_server |
| bool | available_cancel_response |
| bool | available_feedback |
| bool | available_goal_response |
| bool | available_result_response |
| bool | goal_accepted |
| bool | goal_cancelled |
| unique_identifier_msgs__msg__UUID | goal_id |
| struct rclc_action_goal_handle_t * | next |
| void * | ros_goal_request |
| rcl_action_goal_state_t | status |
Detailed Description
rclc's rclc_action_goal_handle_t (phase-515 C4b): one goal of an rclc action server, handed to the goal and cancel callbacks and back to rclc_action_send_result / rclc_action_publish_feedback.
ADOPT-BOUNDED: rclc's members a server reads are here with rclc's names and types (status, goal_id, ros_goal_request, goal_accepted, goal_cancelled, action_server). ros_goal_request is a void * (rclc types it struct Generic_SendGoal_Request *; both are cast to the user's <Action>_SendGoal_Request *). rclc's request headers and its action-client member are not: the runtime answers each request itself, and rclc's typed action client is not ported. The handles live in the server (at most NROS_MAX_CONCURRENT_GOALS), not in executor-allocated memory.
Field Documentation
◆ _in_use
| bool rclc_action_goal_handle_t::_in_use |
Ours: the handle holds a live goal.
◆ action_server
| struct rcl_action_server_t* rclc_action_goal_handle_t::action_server |
The server this goal arrived on.
◆ available_cancel_response
| bool rclc_action_goal_handle_t::available_cancel_response |
rclc's flag; not set by a server.
◆ available_feedback
| bool rclc_action_goal_handle_t::available_feedback |
rclc's flag; not set by a server.
◆ available_goal_response
| bool rclc_action_goal_handle_t::available_goal_response |
rclc's flag; not set by a server.
◆ available_result_response
| bool rclc_action_goal_handle_t::available_result_response |
rclc's flag; not set by a server.
◆ goal_accepted
| bool rclc_action_goal_handle_t::goal_accepted |
true once the goal callback accepted the goal.
◆ goal_cancelled
| bool rclc_action_goal_handle_t::goal_cancelled |
true once the cancel callback accepted a cancel request for this goal.
◆ goal_id
| unique_identifier_msgs__msg__UUID rclc_action_goal_handle_t::goal_id |
The goal's id.
◆ next
| struct rclc_action_goal_handle_t* rclc_action_goal_handle_t::next |
rclc's free/used list link. Always NULL here: the pool is an array.
◆ ros_goal_request
| void* rclc_action_goal_handle_t::ros_goal_request |
The caller's <Action>_SendGoal_Request this goal was deserialised into, an element of the array rclc_executor_add_action_server took.
◆ status
| rcl_action_goal_state_t rclc_action_goal_handle_t::status |
The goal's status. GOAL_STATE_EXECUTING once accepted, GOAL_STATE_CANCELING while a cancel request is being decided or has been accepted, terminal once rclc_action_send_result sent it.
The documentation for this struct was generated from the following file:
- include/rclc/detail/nros_generated.h
